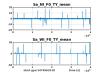
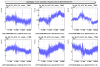
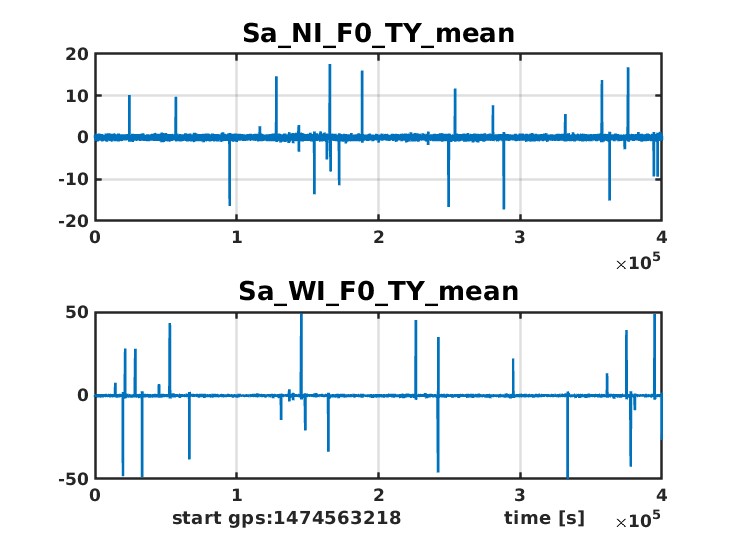
Fig 1 shows that NI and WI inertial control of IP are going through a bad time. The shown period is just the lates 5 days, but the situation has been like this for a long time. This situation is happening more and more often in general indifference, although it is quite simple to spot: the IP rotational dof is quite insensitive to external actions, so a sudden excess motion (up to 100 times more the normal rms) is almost for sure due to a control problem. The direct reason is known: a fast glitch on the accelerometers; a deeper explanation and a permanent solution has never been proposed.
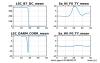
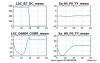
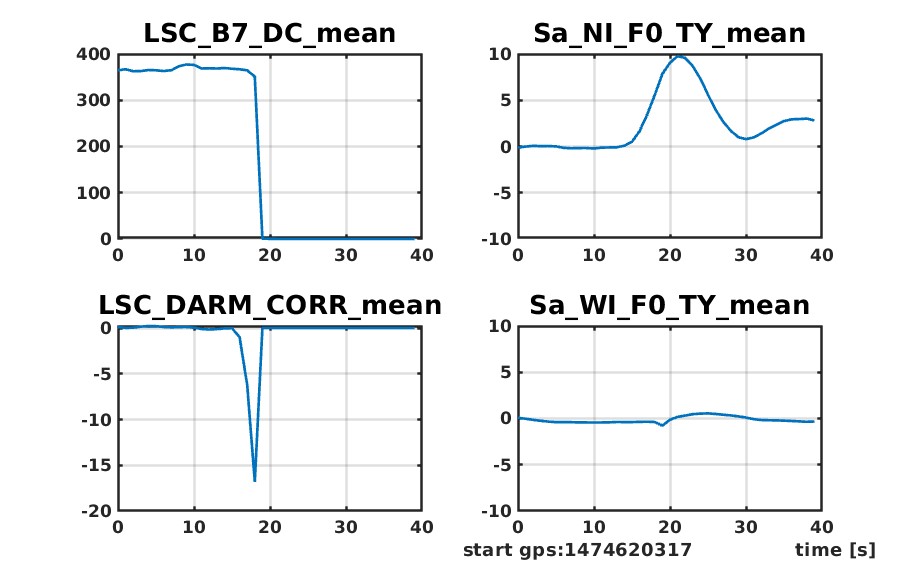
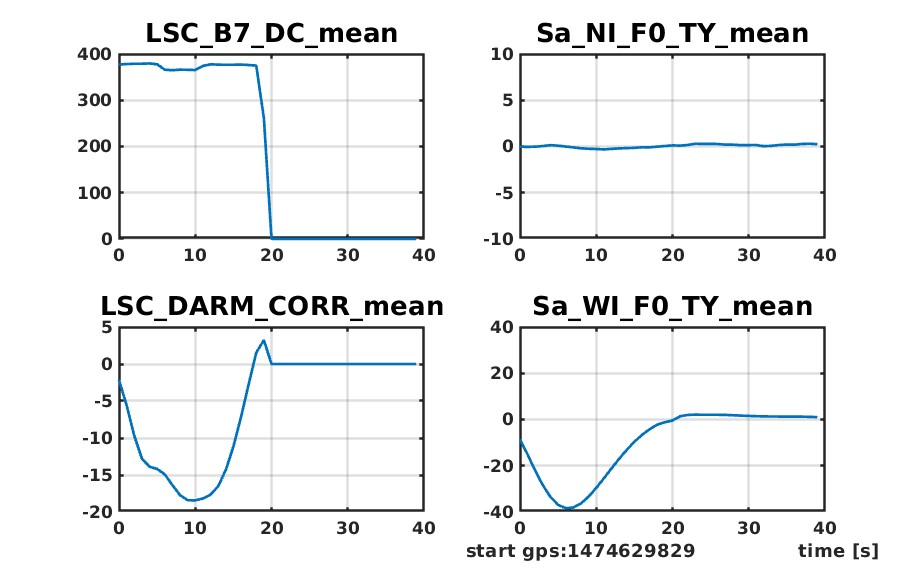
I made a fast quantification of the impact of this situation on locking stability. In the latest 5 days one can count 34 lock losses from locking index larger than 45 (lock acquisition started). Among them, 7 are due to NI glitches; 3 are due to WI glitches: 30% of the total unlocks. Fig 2 and fig 3 show the dynamic of the unlocks: the rotational event is obviously associated to a large longitudinal motion, which lead the locking correction to saturation. To be noticed that the large IP rotation is never due to the unlock: if NI moves, ITF unlocks and no effect is visible on WI. Viceversa, in WI type unlocks, NI remains quiet.